Coding agents as control designers: rendered attempts
53 tasks · for each, the best agent attempt and one attempt per failure mode, re-run on public seeds. Built by scripts/portal.py.
This page accompanies a paper on coding agents as control designers. Each task below asks an agent (Claude Code with Opus 5.5, Fable 5.1 or Sonnet 5.5; one session of at most an hour; no neural networks) to write a feedback controller for a simulated plant, and grades the file on held-out seeds. Every video re-runs the final controller of one session through the task's own evaluator on a public seed; the table under it is the official grade on the held-out seeds. For each task the best attempt is shown and one attempt per failure mode, and for a few solved tasks the weakest passing attempt as well. A few clips come from an earlier sweep with other models under a different harness; their pages say so. The exploration tasks at the end were built after the paper's sweep and are not in its main counts. The tasks, the controllers with their grades and the scripts that build this page are released with the paper.
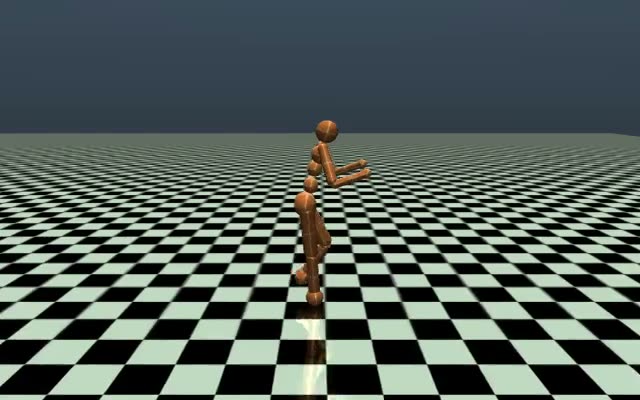
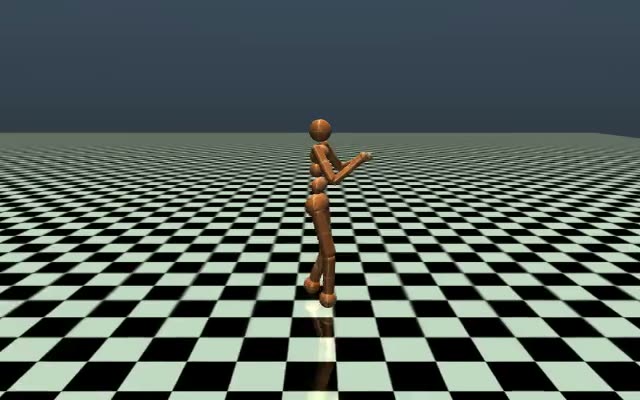
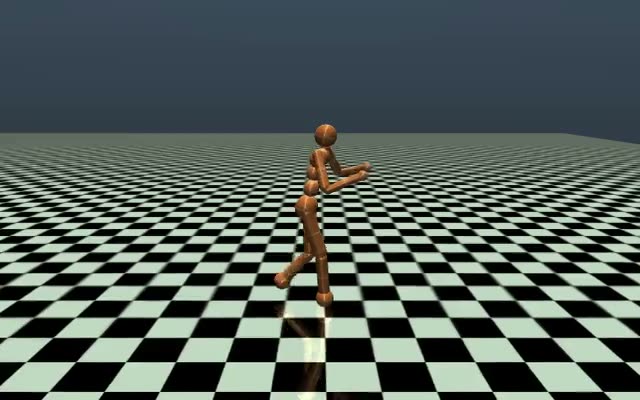
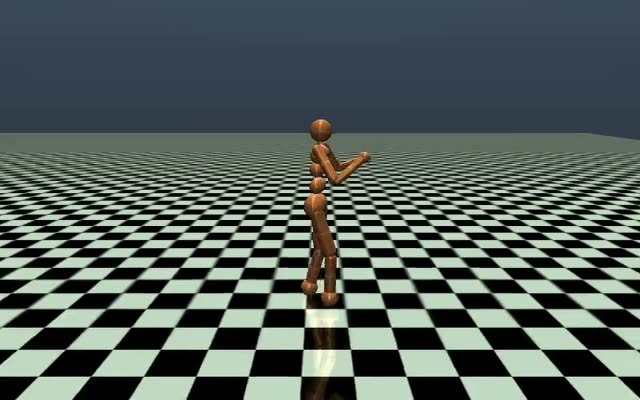
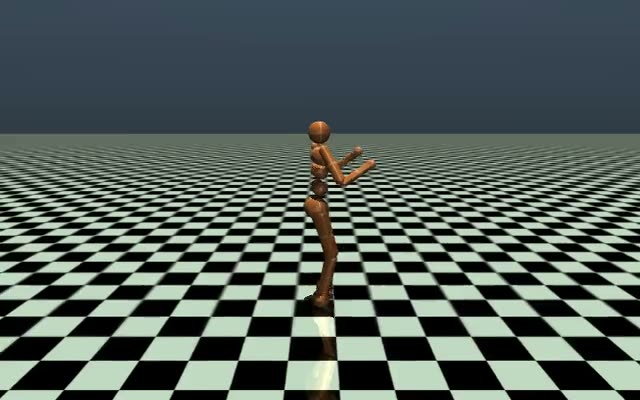
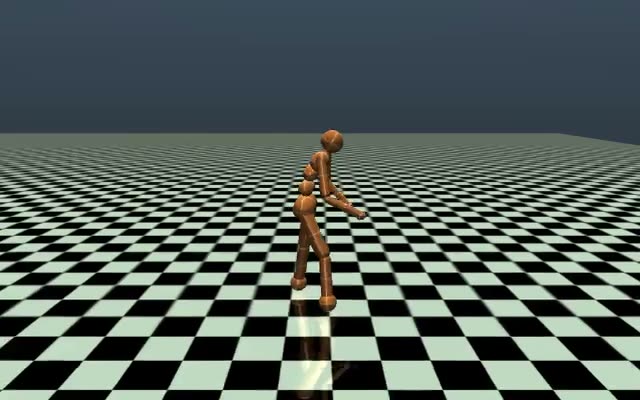
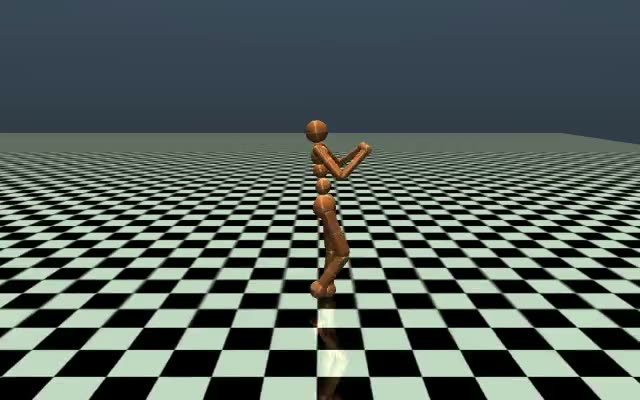
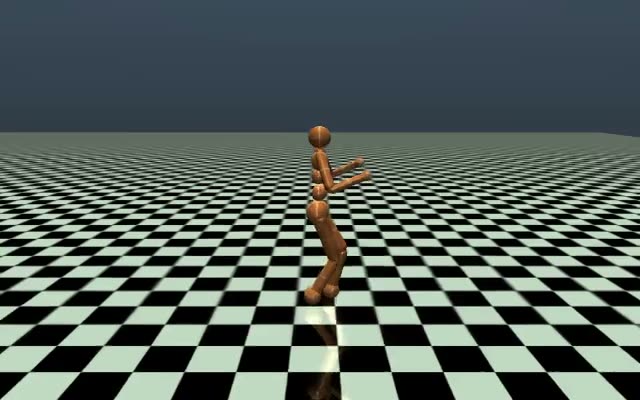
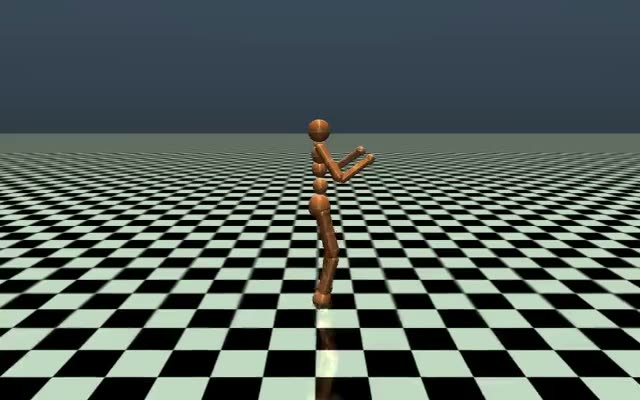
Humanoid (MuJoCo Humanoid-v5)
17 motors, 3D biped; walk without falling, fast, under pushes and changed physics
Hopper (MuJoCo Hopper-v5)
one-legged planar hopper; hop forward, fast, under changed physics
Walker2d (MuJoCo Walker2d-v5)
planar biped with six motors; walk, run, under changed physics
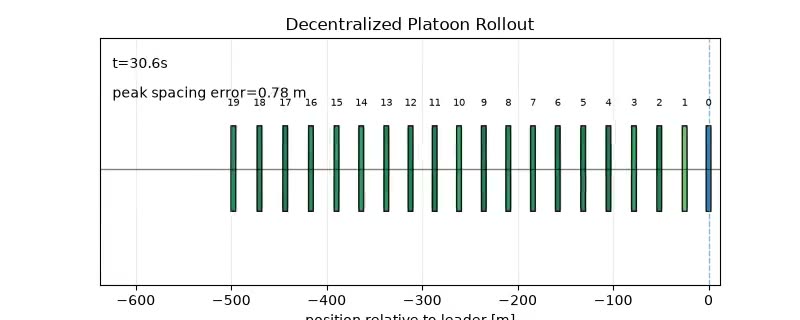
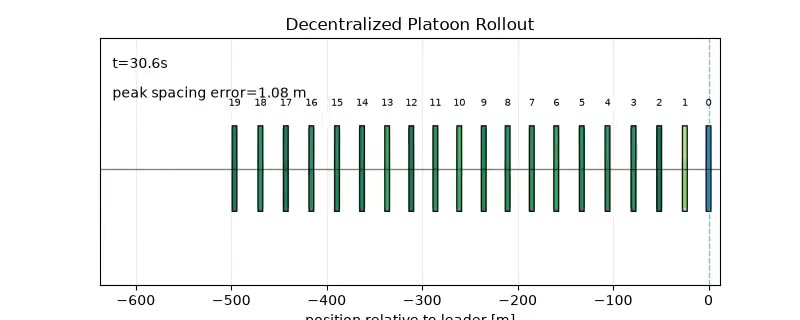
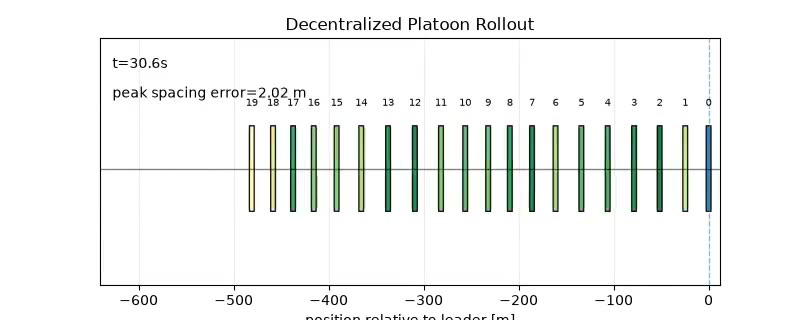
Vehicle platoon
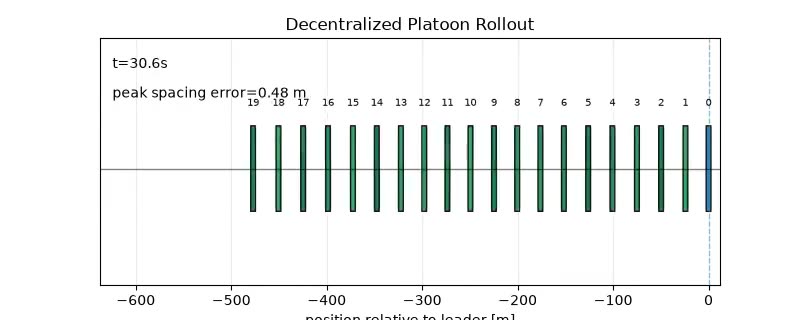
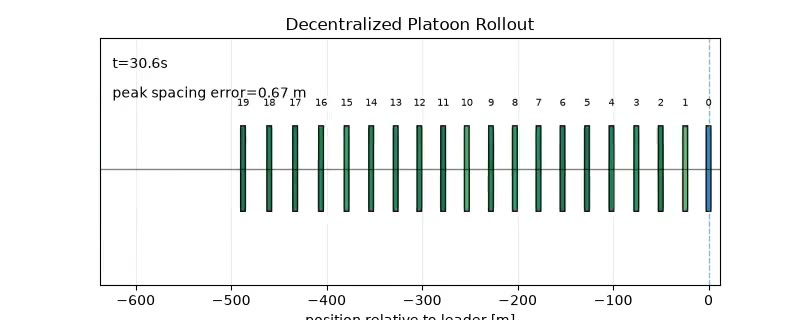
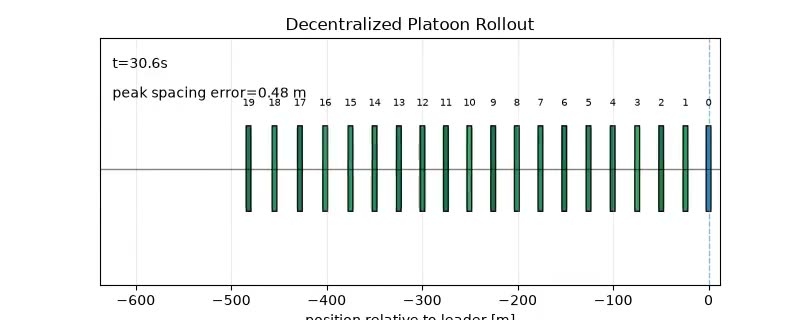
20 vehicles following a braking leader with delayed, noisy local measurements; no collision, string stability
Crowd evacuation
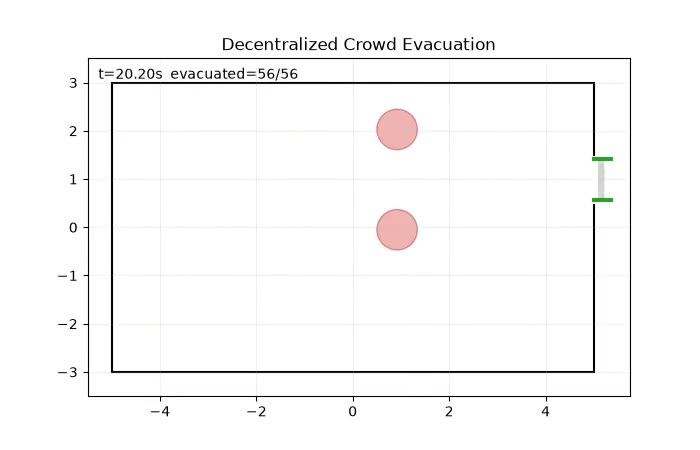
decentralised agents leaving a room through a narrow exit, zero collisions
Lunar lander (Box2D)
continuous-thrust landing between the flags, nominal and perturbed engines/gravity
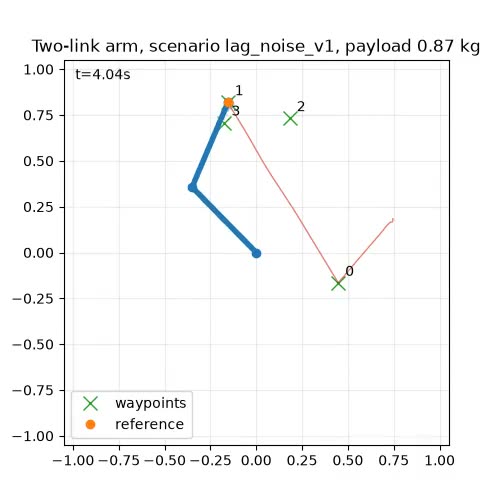
Two-link arm
planar arm visiting task-space waypoints with actuator lag and an unknown payload
Cart-link swing-up
underactuated cart and link: swing up and hold upright within force and track limits
Inverted pendulum swing-up
torque-limited pendulum: swing up and hold
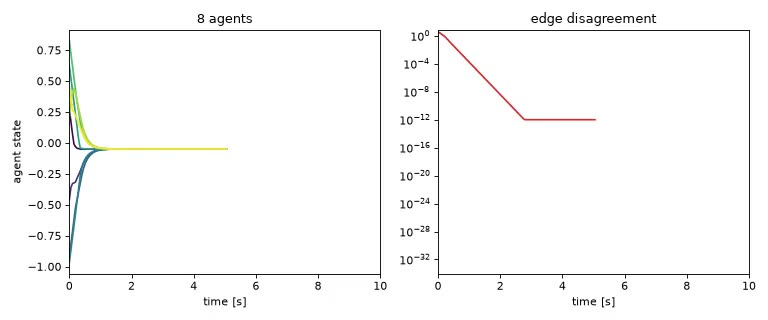
Consensus
single-integrator agents on a ring graph reaching agreement
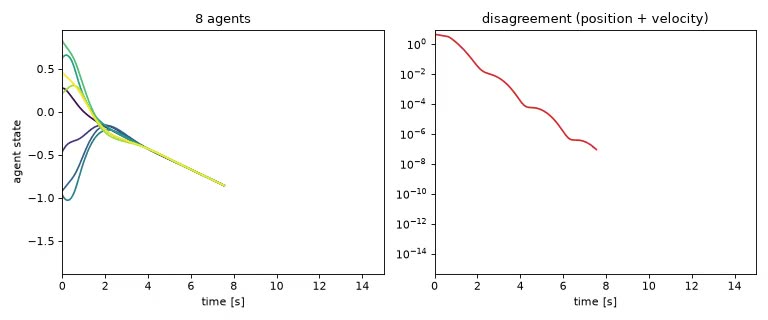
Second-order consensus
double-integrator agents agreeing on position and velocity
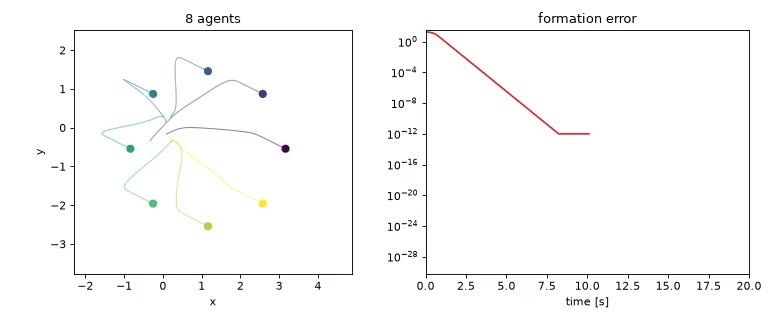
Formation control
planar agents forming a circle while avoiding collisions
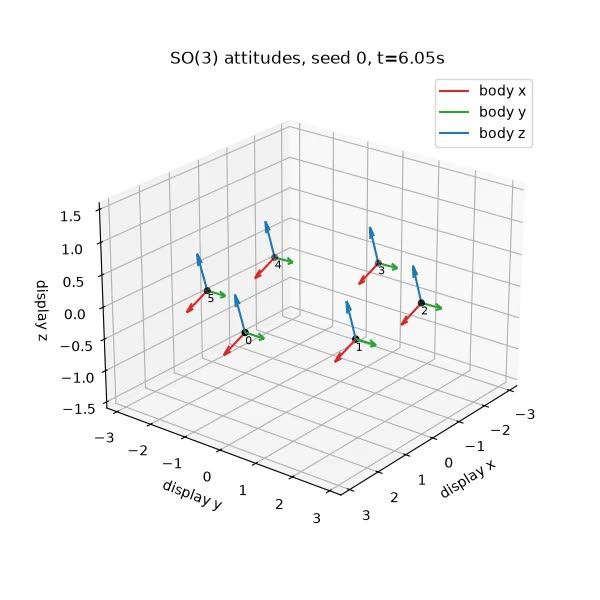
SO(3) attitude synchronisation
rigid bodies on a ring aligning their orientations
Exploration tasks (outside the paper's main sweep)
Built after the paper's sweep to test whether a task can force a mechanism outside the catalogue (docs/exploration_new_mechanisms.md, docs/soft_arm_spec.md). Not part of the benchmark tiers or of the paper's main counts; the soft arm is reported in the paper as a plant outside the sweep, the other tasks are not; all sessions ran under the paper's protocol.
Hopper (MuJoCo Hopper-v5)
one-legged planar hopper; hop forward, fast, under changed physics
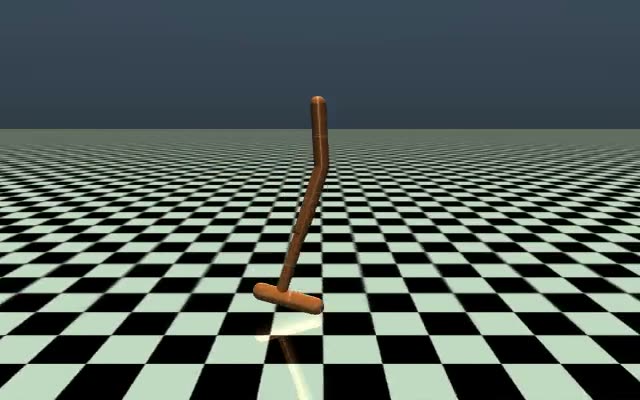
Walker2d (MuJoCo Walker2d-v5)
planar biped with six motors; walk, run, under changed physics
Inverted pendulum swing-up
torque-limited pendulum: swing up and hold
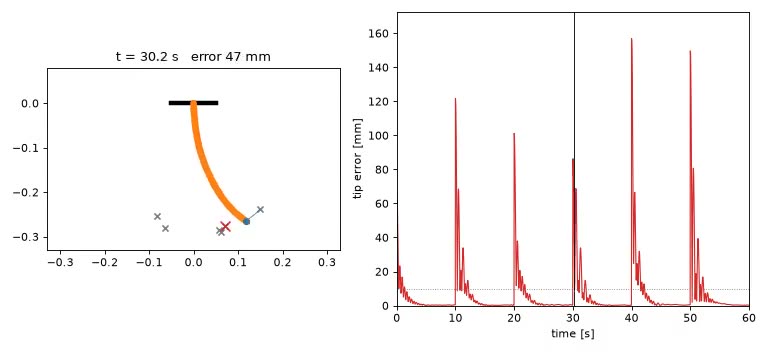
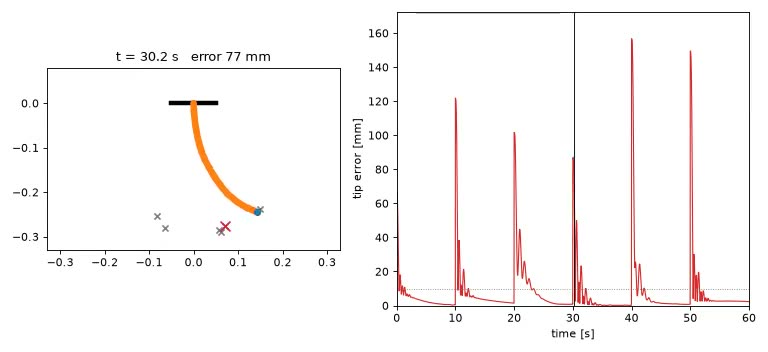
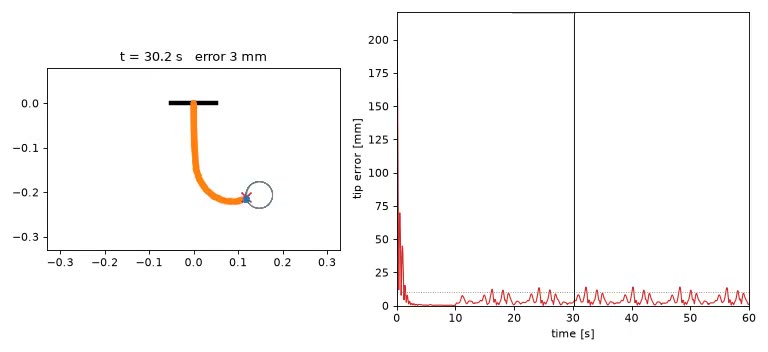
Soft continuum arm
two-segment pneumatic silicone arm hanging under gravity, with creep, hysteresis, pressure lag and a different material every seed, seen by a 25 Hz tip camera; reach and hold targets, track a circle